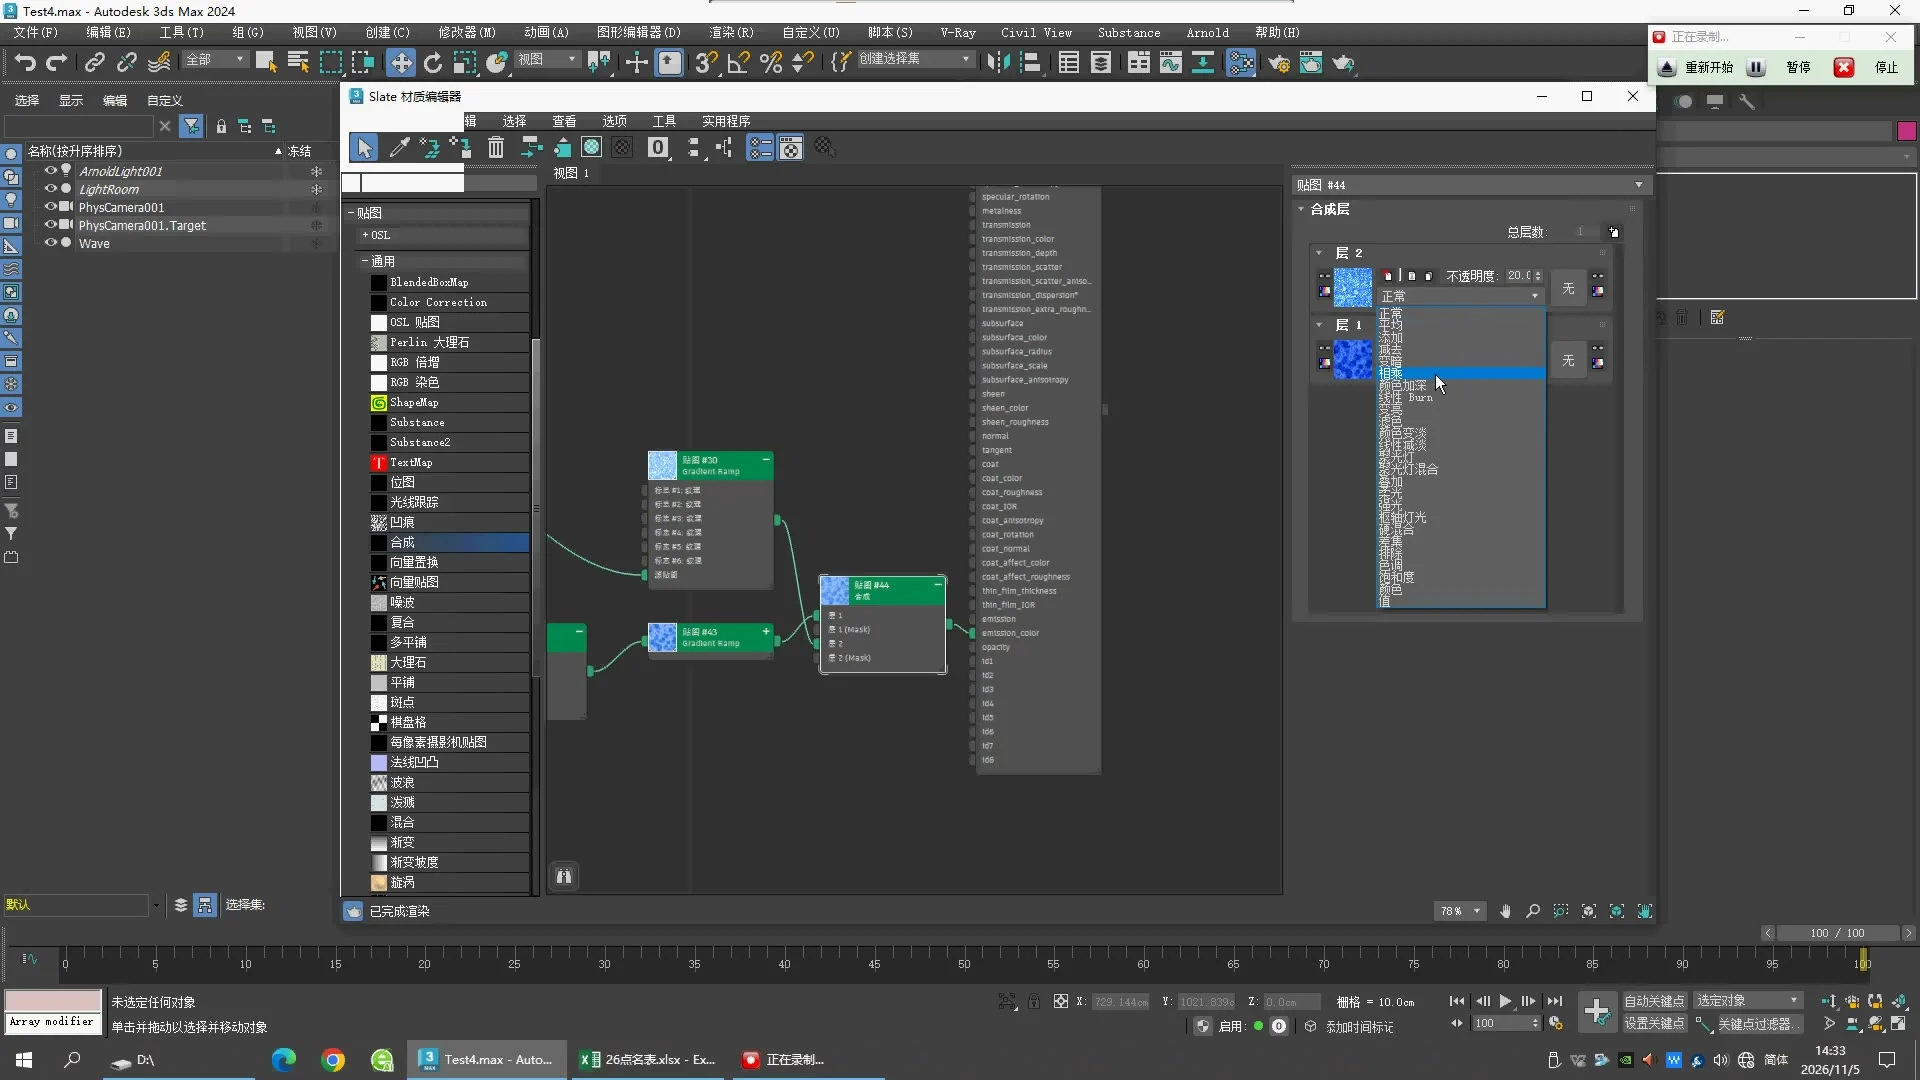
Cellular water — source scene recovered 这节课换成 Cellular 水面,然后把上一节的线性条纹少量混回来。先学灰度图案,再学蓝色映射,最后加动画。以下数值来自本机 [本机资料路径] 的实际读取;它是包含后续水滴的保存版本,不代表视频每个中间时刻。
Download editable Test4_Source_Study.max · Full parameter and key readback
原工程未修改,SHA-256 前后相同。学习副本已通过 Max 的 Save As 保存。下方另有水面观察镜头副本和三帧渲染。水面 101 帧已完成;雨滴考核仍未完成。
1 · Create the surface Plane 名称 Wave ,Length / Width = 400 cm ,Length Segs / Width Segs = 1 / 1 ,Z = 5 cm 。保留 Generate Mapping Coords。源场景还有 LightRoom、两个 Arnold Lights 和 Sphere001 水滴;没有保存 Camera 对象,不能声称恢复了老师镜头。
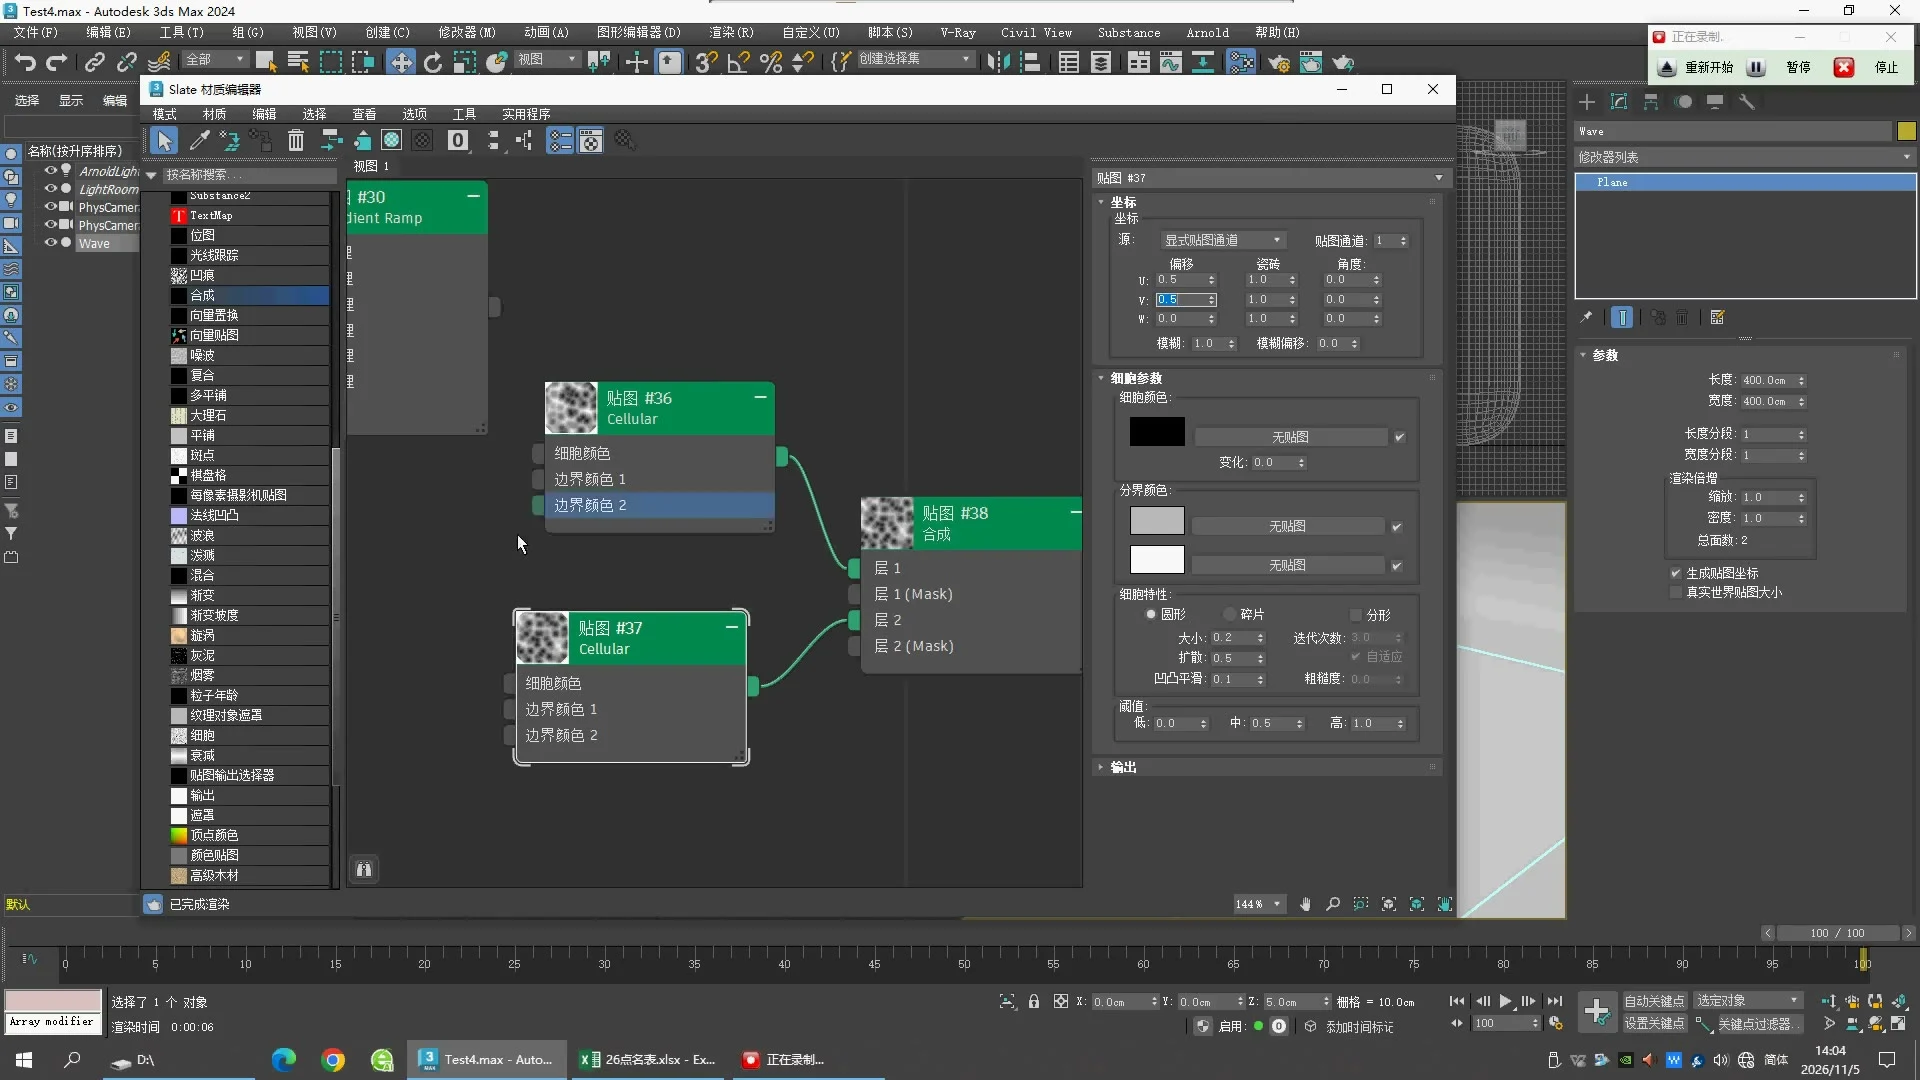
2 · Make the cell pattern 在 Slate 创建 Cellular #36 ,复制为 #37 。两者 Size = 0.2 ,Spread = 0.5 ,Fractal = Off,Coordinates 使用 Explicit Map Channel 1 。#37 的 Offset = (0.5, 0.5, 0.2),W Angle = 90°(Frame 0)。黑色中心和亮边界形成不规则区域。两个方向叠加,使水面不只是一排重复图案。
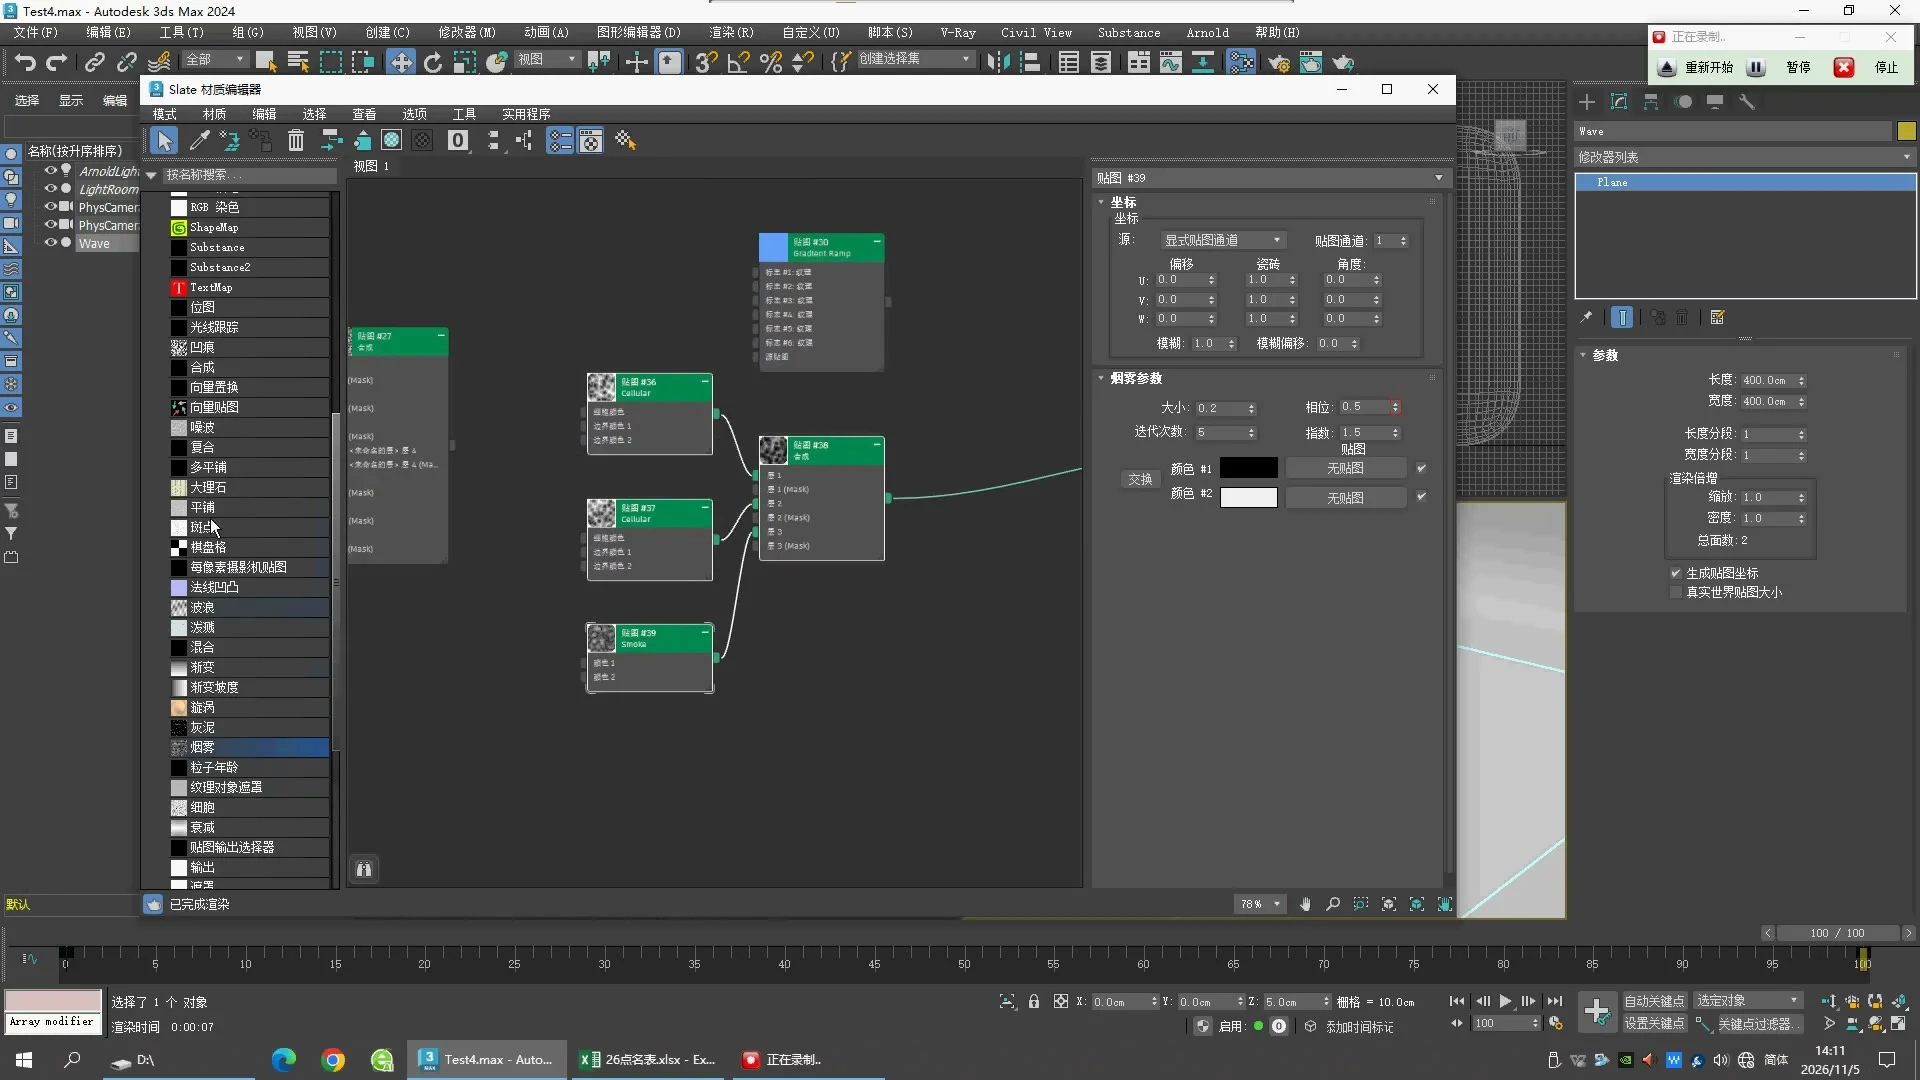
3 · Composite #38 Layer Map Blend Mode Opacity 1 Cellular #36 Normal 100% 2 Cellular #37 Overlay 100% 3 Smoke #39 Multiply 70%
Smoke #39 使用 Explicit Map Channel 1、Size 0.2、Iterations 5、Exponent 1.5。Multiply 层把部分区域压暗。练习时先关闭 Auto Key,把这一层 Opacity 改为 0,观察差异,然后恢复 70。
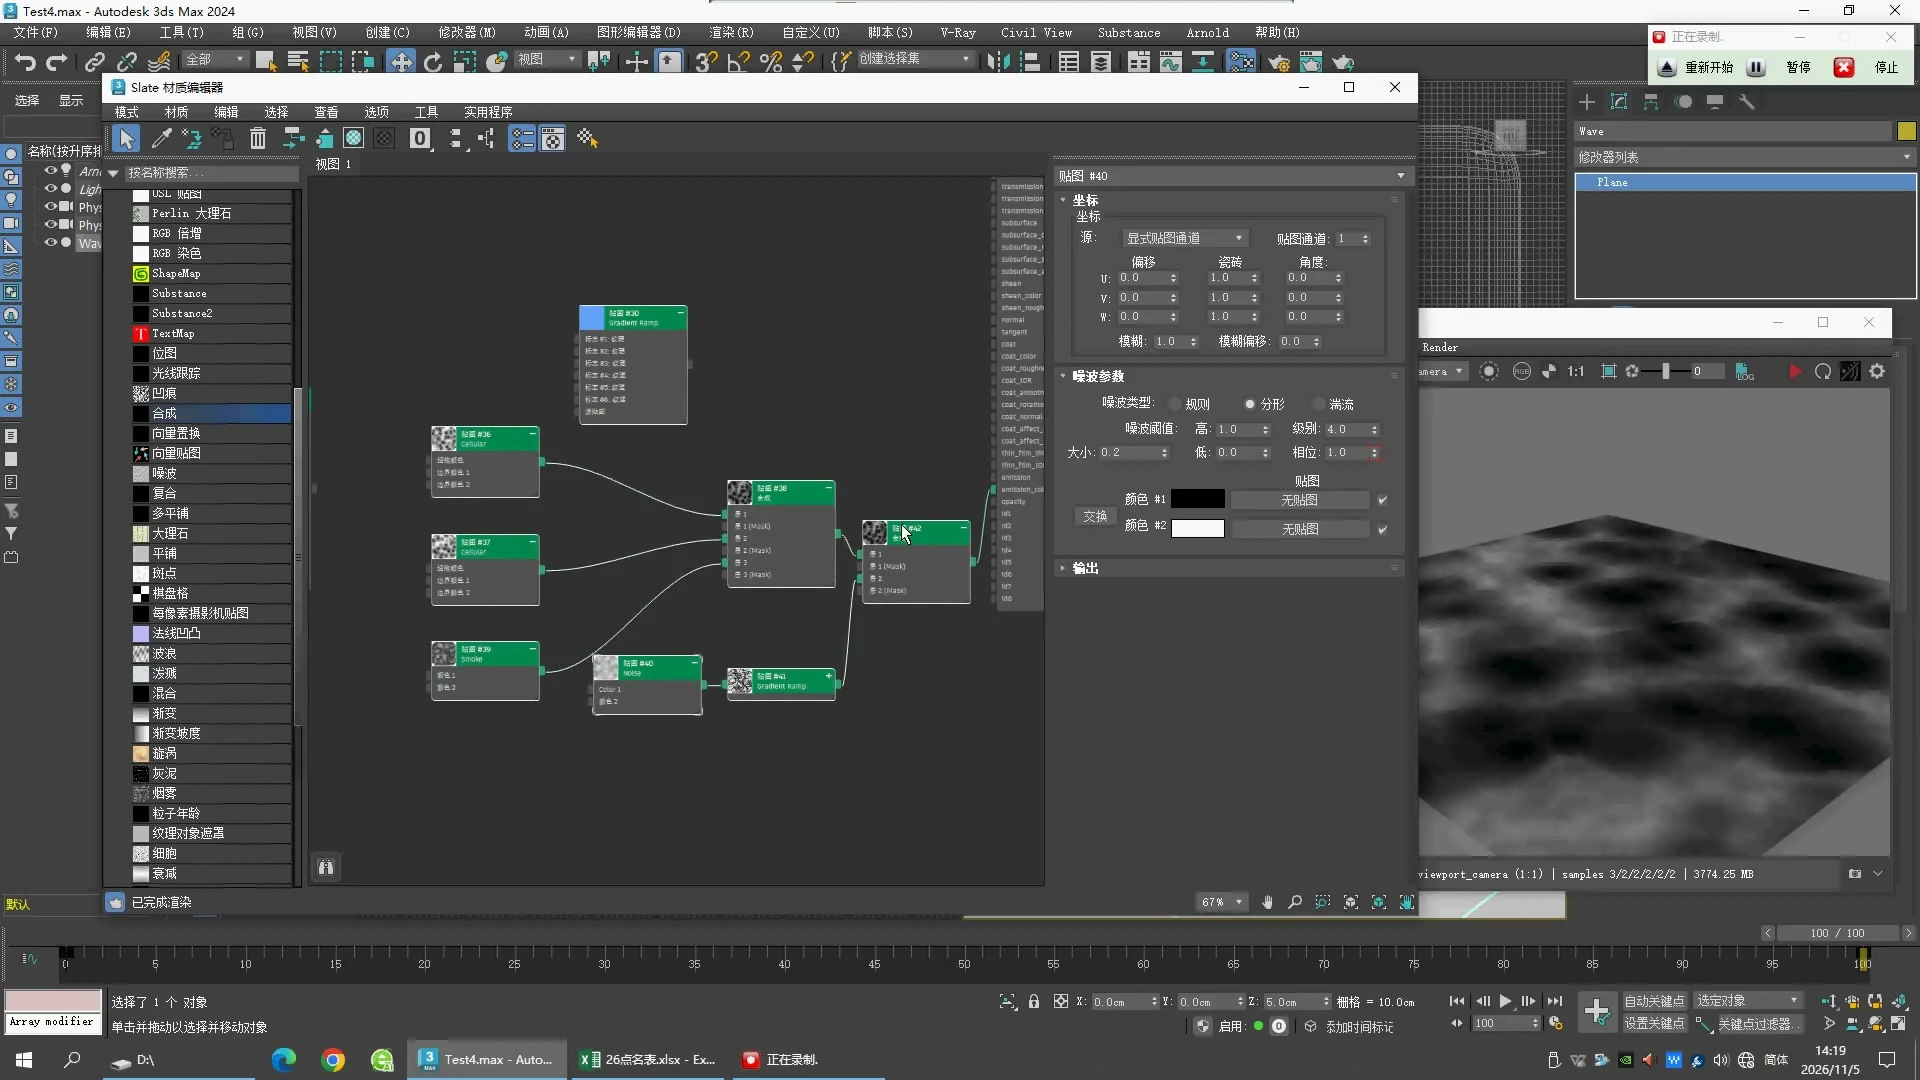
4 · Add fine details Noise #40 → Source Map of Gradient Ramp #41 。#41 用 Mapped,把 Noise 的灰度重新分配为多条明暗带。源工程保存的 #41 Noise Amount 是 0.12 ,Size = 0.8 ;视频中途出现的 0.1 不等于最后保存值。
Composite Layer 1 Layer 2 Layer 2 Opacity #42 #38 / Normal #41 / Linear Dodge 5% #44 #43 / Normal #30 / Screen 10%
#42 的细节只混 5%,不要用课堂试调时的 100% 替代最终值。#44 的 #30 是上一节线性水面,不是新建的空白贴图。
5 · Turn grayscale into blue #36 + #37 + #39 → Composite #38 ─┐
Noise #40 → Mapped Ramp #41 ────┤ Composite #42
↓
Mapped blue Ramp #43
↓
Composite #44 (+ previous #30 at 10%)
↓
Water → Emission Color Water 是 Arnold Standard Surface 。Base = 0,Specular = 0,Emission = 0.5。蓝色来自 Emission Color 的节点链。此路径不能单独证明有几何起伏或 Displacement。
6 · Animate the texture 下面是实际 Controller 的关键帧,不是仅凭截图猜的数值。建议先保存副本,在 Frame 0 建第一个值,开启 Auto Key,移到 Frame 100 设置第二个值,再关闭 Auto Key。在 Curve Editor 核对 Tangents。
Map Track Keys In / Out Tangent #36 贴图 #36/Coordinates/offset 0f = [0,0,0]; 100f = [0,0,0.3] linear/linear #37 贴图 #37/Coordinates/offset 0f = [0.5,0.5,0.2]; 100f = [0.5,0.5,0.5] linear/linear #39 贴图 #39/phase 0f = 0.0; 100f = 0.5 linear/linear #40 贴图 #40/phase 0f = 0.0; 100f = 1.0 linear/linear #25 贴图 #25/Coordinates/U_Offset 0f = 0.0; 100f = 0.25 linear/linear #25 贴图 #25/parameters/phase 0f = 0.0; 100f = 0.5 linear/linear #26 贴图 #26/Coordinates/U_Offset 0f = 0.0; 100f = 0.30000001192092896 linear/linear #26 贴图 #26/parameters/phase 0f = 0.0; 100f = 0.30000001192092896 linear/linear #28 贴图 #28/Coordinates/U_Offset 0f = 0.0; 100f = 0.18000000715255737 linear/linear #28 贴图 #28/parameters/phase 0f = 0.0; 100f = 0.6000000238418579 linear/linear #29 贴图 #29/Coordinates/offset 0f = [0,0,0]; 100f = [0,0.5,0] linear/linear #29 贴图 #29/phase 0f = 0.0; 100f = 0.10000000149011612 linear/linear
Offset 让纹理采样位置改变;Phase 让噪波形态演变。它们不移动 Plane。Cellular #36 在 Frame 18 的 W Offset 实读 0.054,在 Frame 66 是 0.198,在 Frame 100 是 0.3,与线性变化一致。
Exact saved-node values 展开查看原生属性。数值保留浮点精度;颜色是源工程存储的通道值,不是从截图吸取的屏幕颜色。Gradient Ramp 的第一个/第二个端点 Position 固定为 0/100,未暴露 Position 属性时按端点标明。不要把这些色标的列表顺序当位置排序。
#36 · Cellular · saved values Property Stored value cellColor (color 0 0 0) divColor1 (color 127.5 127.5 127.5) divColor2 (color 255 255 255) CellMap None divMap1 None divMap2 None map1Enabled True map2Enabled True map3Enabled True variation 0.0 size 0.20000000298023224 spread 0.5 lowThresh 0.0 midThresh 0.5 highThresh 1.0 type 0 fractal False iteration 3.0 roughness 0.0 smooth 0.10000000149011612 adaptive True coords MtlBase:Placement output MtlBase:Output
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
#37 · Cellular · saved values Property Stored value cellColor (color 0 0 0) divColor1 (color 127.5 127.5 127.5) divColor2 (color 255 255 255) CellMap None divMap1 None divMap2 None map1Enabled True map2Enabled True map3Enabled True variation 0.0 size 0.20000000298023224 spread 0.5 lowThresh 0.0 midThresh 0.5 highThresh 1.0 type 0 fractal False iteration 3.0 roughness 0.0 smooth 0.10000000149011612 adaptive True coords MtlBase:Placement output MtlBase:Output
Coordinates Property Stored value blur 1.0 offset [0.5,0.5,0.2] angle [0,0,90] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
Coordinates Property Stored value blur 1.0 offset [0.5,0.5,0.2] angle [0,0,90] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
#39 · Smoke · saved values Property Stored value size 0.20000000298023224 iterations 5 Exponent 1.5 phase 0.0 color1 (color 0 0 0) color2 (color 229.5 229.5 229.5) map1 None map2 None map1On True map2On True coords MtlBase:Placement
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
#40 · Noise · saved values Property Stored value color1 (color 0 0 0) color2 (color 255 255 255) map1 None map2 None map1Enabled True map2Enabled True size 0.20000000298023224 phase 0.0 Levels 4.0 thresholdLow 0.0 thresholdHigh 1.0 type 1 coords MtlBase:Placement output MtlBase:Output
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
#41 · Gradient_Ramp · saved values Property Stored value size 0.800000011920929 phase 0.0 amount 0.11999999731779099 Levels 4.0 Low_Threshold 0.0 High_Threshold 1.0 Threshold_Smoothing 0.0 Gradient_Type 5 Noise_Type 1 Source_Map_On 1 Coordinates MtlBase:Placement output MtlBase:Output Gradient_Ramp ReferenceTarget:JData Source_Map 贴图 #40:Noise
Coordinates Property Stored value blur 1.0 mapping 0 mapChannel 1 mappingType 0 UVW_Type 0 U_Mirror False V_Mirror False U_Tile True V_Tile True showMapOnBack True Noise_On False Noise_Animate False UVTransform (matrix3 [1,0,0] [0,1,0] [0,0,1] [0,0,0]) realWorldScale False realWorldHeight 1.0 realWorldWidth 1.0 phase 0.0 U_Offset 0.0 V_Offset 0.0 U_Tiling 1.0 V_Tiling 1.0 U_Angle 0.0 V_Angle 0.0 W_Angle 0.0 Noise_Amount 1.0 Noise_Size 1.0 Noise_Levels 1 Blur_Offset 0.0
Gradient flags Flag Position Color 标志__1 0 (endpoint) [13.0361,13.0361,13.0361] 标志__2 100 (endpoint) [15.3081,15.3081,15.3081] 标志__3 50.0 [31.875,31.875,31.875] 标志__4 8.7542085647583 [255,255,255] 标志__5 21.212121963500977 [21.0156,21.0156,21.0156] 标志__6 36.70033645629883 [255,255,255] 标志__7 72.05387115478516 [255,255,255] 标志__8 80.8080825805664 [6.17685,6.17685,6.17685] 标志__9 91.919189453125 [255,255,255] 标志__10 26.93602752685547 [0.942796,0.942796,0.942796] 标志__11 45.11784744262695 [31.8089,31.8089,31.8089] 标志__12 60.26936340332031 [122.898,122.898,122.898] 标志__13 3.0303030014038086 [0,0,0] 标志__14 96.63299560546875 [0,0,0] 标志__15 55.21885681152344 [11.3609,11.3609,11.3609] 标志__16 65.31986236572266 [255,255,255]
#43 · Gradient_Ramp · saved values Property Stored value size 2.0 phase 0.0 amount 0.10000000149011612 Levels 4.0 Low_Threshold 0.0 High_Threshold 1.0 Threshold_Smoothing 0.0 Gradient_Type 5 Noise_Type 0 Source_Map_On 1 Coordinates MtlBase:Placement output MtlBase:Output Gradient_Ramp ReferenceTarget:JData Source_Map 贴图 #42:Composite
Coordinates Property Stored value blur 1.0 mapping 0 mapChannel 1 mappingType 0 UVW_Type 0 U_Mirror False V_Mirror False U_Tile True V_Tile True showMapOnBack True Noise_On False Noise_Animate False UVTransform (matrix3 [1,0,0] [0,1,0] [0,0,1] [0,0,0]) realWorldScale False realWorldHeight 1.0 realWorldWidth 1.0 phase 0.0 U_Offset 0.0 V_Offset 0.0 U_Tiling 1.0 V_Tiling 1.0 U_Angle 0.0 V_Angle 0.0 W_Angle 0.0 Noise_Amount 1.0 Noise_Size 1.0 Noise_Levels 1 Blur_Offset 0.0
Gradient flags Flag Position Color 标志__1 0 (endpoint) [3.22925,38.5198,161.171] 标志__2 100 (endpoint) [162.889,241.986,255] 标志__3 8.08080768585205 [32.5201,91.4568,227.272] 标志__4 55.21885681152344 [86.502,161.171,255] 标志__5 3.7037036418914795 [11.768,54.0713,223.16] 标志__6 24.91582489013672 [88.9605,144.537,255] 标志__7 43.43434143066406 [0.253055,51.2794,180.616] 标志__8 46.12794494628906 [4.09726,80.5195,255] 标志__9 37.03703689575195 [71.7632,122.938,232.307] 标志__10 30.639732360839844 [48.568,107.23,241.986] 标志__11 72.7272720336914 [25.1657,173.405,255]
#30 · Gradient_Ramp · saved values Property Stored value size 1.0 phase 0.0 amount 0.0 Levels 4.0 Low_Threshold 0.0 High_Threshold 1.0 Threshold_Smoothing 0.0 Gradient_Type 5 Noise_Type 0 Source_Map_On 1 Coordinates MtlBase:Placement output MtlBase:Output Gradient_Ramp ReferenceTarget:JData Source_Map 贴图 #27:Composite
Coordinates Property Stored value blur 1.0 mapping 0 mapChannel 1 mappingType 0 UVW_Type 0 U_Mirror False V_Mirror False U_Tile True V_Tile True showMapOnBack True Noise_On False Noise_Animate False UVTransform (matrix3 [1,0,0] [0,1,0] [0,0,1] [0,0,0]) realWorldScale False realWorldHeight 1.0 realWorldWidth 1.0 phase 0.0 U_Offset 0.0 V_Offset 0.0 U_Tiling 1.0 V_Tiling 1.0 U_Angle 0.0 V_Angle 0.0 W_Angle 0.0 Noise_Amount 1.0 Noise_Size 1.0 Noise_Levels 1 Blur_Offset 0.0
Gradient flags Flag Position Color 标志__1 0 (endpoint) [34.7051,91.4568,255] 标志__2 100 (endpoint) [239.853,252.805,255] 标志__3 35.69023513793945 [28.3814,136.589,255] 标志__4 56.56565475463867 [248.447,252.805,255] 标志__5 81.81818389892578 [41.7284,195.52,255] 标志__6 15.15151596069336 [118.509,187.987,255]
#25 · Gradient_Ramp · saved values Property Stored value size 5.0 phase 0.0 amount 0.5 Levels 4.0 Low_Threshold 0.0 High_Threshold 1.0 Threshold_Smoothing 0.0 Gradient_Type 4 Noise_Type 0 Source_Map_On 1 Coordinates MtlBase:Placement output MtlBase:Output Gradient_Ramp ReferenceTarget:JData
Coordinates Property Stored value blur 1.0 mapping 0 mapChannel 1 mappingType 0 UVW_Type 0 U_Mirror True V_Mirror False U_Tile False V_Tile True showMapOnBack True Noise_On False Noise_Animate False UVTransform (matrix3 [10,0,0] [0,1,0] [0,0,1] [-4.5,0,0]) realWorldScale False realWorldHeight 1.0 realWorldWidth 0.10000000149011612 phase 0.0 U_Offset 0.0 V_Offset 0.0 U_Tiling 10.0 V_Tiling 1.0 U_Angle 0.0 V_Angle 0.0 W_Angle 0.0 Noise_Amount 1.0 Noise_Size 1.0 Noise_Levels 1 Blur_Offset 0.0
Gradient flags Flag Position Color 标志__1 0 (endpoint) [0,0,0] 标志__2 100 (endpoint) [255,255,255] 标志__3 50.0 [127.5,127.5,127.5]
#26 · Gradient_Ramp · saved values Property Stored value size 5.0 phase 0.0 amount 0.5 Levels 4.0 Low_Threshold 0.0 High_Threshold 1.0 Threshold_Smoothing 0.0 Gradient_Type 4 Noise_Type 0 Source_Map_On 1 Coordinates MtlBase:Placement output MtlBase:Output Gradient_Ramp ReferenceTarget:JData
Coordinates Property Stored value blur 1.0 mapping 0 mapChannel 1 mappingType 0 UVW_Type 0 U_Mirror True V_Mirror False U_Tile False V_Tile True showMapOnBack True Noise_On False Noise_Animate False UVTransform (matrix3 [11.2583,0.5,0] [-6.5,0.866025,0] [0,0,1] [-1.87916,-0.183013,0]) realWorldScale False realWorldHeight 1.0 realWorldWidth 0.07692307978868484 phase 0.0 U_Offset 0.0 V_Offset 0.0 U_Tiling 13.0 V_Tiling 1.0 U_Angle 0.0 V_Angle 0.0 W_Angle 30.000001907348633 Noise_Amount 1.0 Noise_Size 1.0 Noise_Levels 1 Blur_Offset 0.0
Gradient flags Flag Position Color 标志__1 0 (endpoint) [0,0,0] 标志__2 100 (endpoint) [117.434,117.434,117.434]
#28 · Gradient_Ramp · saved values Property Stored value size 5.0 phase 0.0 amount 0.5 Levels 4.0 Low_Threshold 0.0 High_Threshold 1.0 Threshold_Smoothing 0.0 Gradient_Type 4 Noise_Type 0 Source_Map_On 1 Coordinates MtlBase:Placement output MtlBase:Output Gradient_Ramp ReferenceTarget:JData
Coordinates Property Stored value blur 1.0 mapping 0 mapChannel 1 mappingType 0 UVW_Type 0 U_Mirror True V_Mirror False U_Tile False V_Tile True showMapOnBack True Noise_On False Noise_Animate False UVTransform (matrix3 [8,0.866025,0] [-13.8564,0.5,0] [0,0,1] [3.4282,-0.183013,0]) realWorldScale False realWorldHeight 1.0 realWorldWidth 0.0625 phase 0.0 U_Offset 0.0 V_Offset 0.0 U_Tiling 16.0 V_Tiling 1.0 U_Angle 0.0 V_Angle 0.0 W_Angle 60.000003814697266 Noise_Amount 1.0 Noise_Size 1.0 Noise_Levels 1 Blur_Offset 0.0
Gradient flags Flag Position Color 标志__1 0 (endpoint) [0,0,0] 标志__2 100 (endpoint) [174.474,174.474,174.474]
#29 · Smoke · saved values Property Stored value size 0.05000000074505806 iterations 5 Exponent 1.0 phase 0.0 color1 (color 0 0 0) color2 (color 255 255 255) map1 None map2 None map1On True map2On True coords MtlBase:Placement
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
Coordinates Property Stored value blur 1.0 offset [0,0,0] angle [0,0,0] coordType 2 mapChannel 1 Blur_Offset 0.0 Tiling [1,1,1]
Follow the source video 本次已检查 97 个约 20 秒间隔画面,并以源工程补齐数值;尚未逐帧审阅所有鼠标操作。以下时间为章节定位入口。
00:10 Cellular: first pattern
02:30 Copy and combine Cellular
05:10 Animate offsets
08:30 Smoke layer / Multiply 70%
10:30 Noise detail
14:10 Mapped Gradient Ramp
17:10 Composite blend experiments
20:10 Blue palette
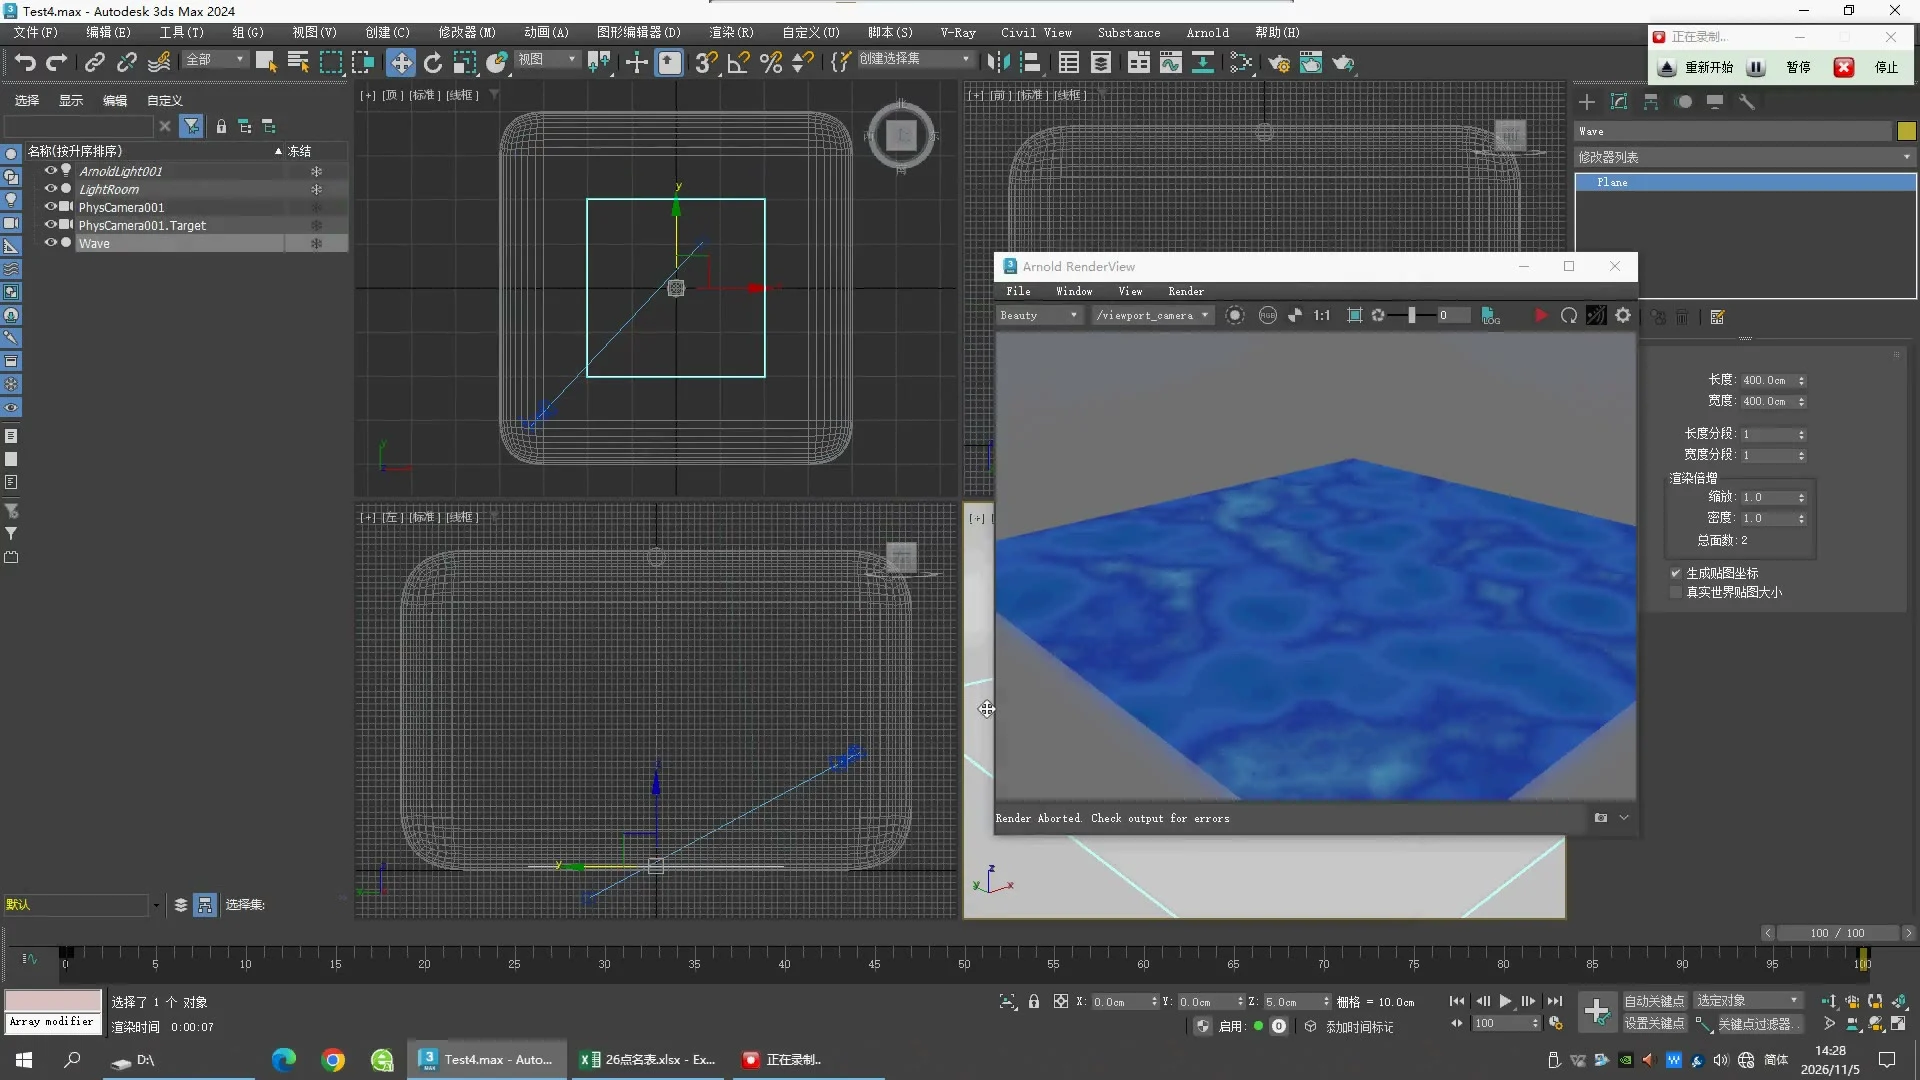
27:10 Water render
30:50 Mix the earlier linear water
版本差异: 用户截图在 Frame 100 显示 #25 U Offset 0.5 / Phase 0.25;此 Test4 源文件则保存 U Offset 0.25 / Phase 0.5。两者分别记录,不能互相冒充。
Complete saved-timeline animation Frame 0–100, every frame rendered in interactive Max, 30 fps, 640×480. Duration 3.37 seconds. Camera is supplemental. Playback does not imply a seamless loop. Frame verification
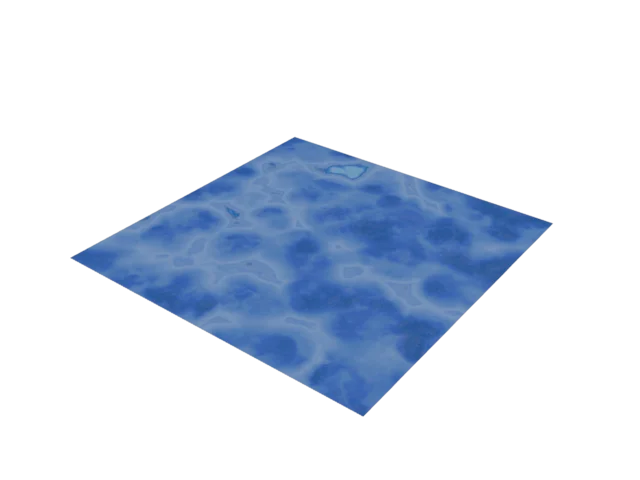
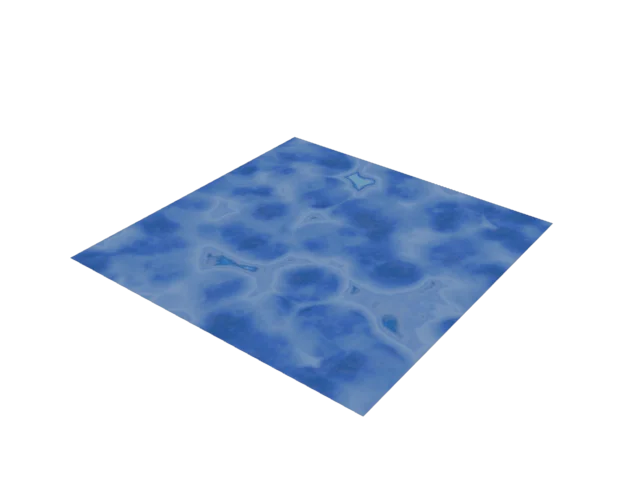
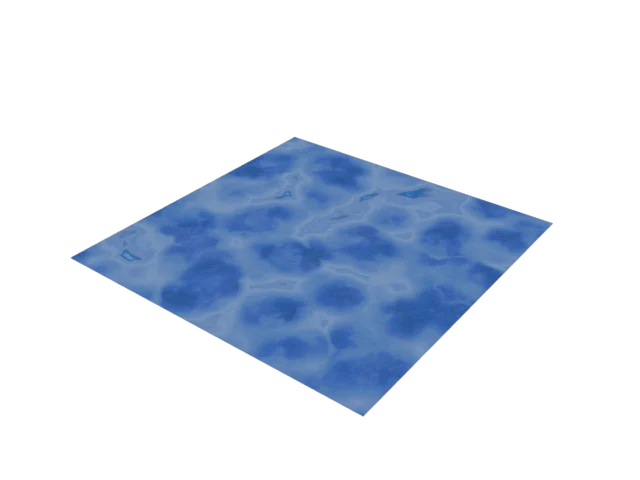
Water-only camera study · rendered in Max 已在现有 Max 窗口通过脚本渲染 Frame 0、50、100,检查到水面纹理随时间变化。无 batch license 水印。下方另有完整 101 帧动画。
Download water-focused MAX · Supplementary camera settings
观察镜头为补充设置:Position (460, −600, 490),Target (0, 0, 5),FOV 45°,640×480。原材质和关键帧保留;其他几何体的 Renderable 在这份单独副本中关闭,以看清水面。原教学副本仍保留。